Ellipse radii and plane angles used by the Woods-Saxon profiles. More...
Functions | |
| double | EllipseUniAxis (double x, double y, double lx, double ly) |
EllipseRotAxis with   | |
| double | EllipseRotAxis (double x, double y, double lx, double ly, double theta) |
Radius of the ellipse with semi-axes    | |
| double | Angle (double x, double y, double centx=0., double centy=0.) |
| Quadrant-aware angle of the point (x, y) about (centx, centy). | |
Detailed Description
Ellipse radii and plane angles used by the Woods-Saxon profiles.
Function Documentation
◆ EllipseUniAxis()
| double QPMath::GeometryCalc::EllipseUniAxis | ( | double | x, |
| double | y, | ||
| double | lx, | ||
| double | ly | ||
| ) |
EllipseRotAxis with
- Parameters
-
x direction component x y direction component y lx semi-axis along x ly semi-axis along y
- Returns
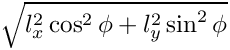
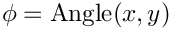

Definition at line 172 of file QPMath.cpp.
References EllipseRotAxis().
Referenced by QPMath::WoodSaxon::UniAxis2D().
◆ EllipseRotAxis()
| double QPMath::GeometryCalc::EllipseRotAxis | ( | double | x, |
| double | y, | ||
| double | lx, | ||
| double | ly, | ||
| double | theta | ||
| ) |
Radius of the ellipse with semi-axes
- Parameters
-
x direction component x y direction component y lx semi-axis along the rotated x axis ly semi-axis along the rotated y axis theta ellipse rotation, radians
- Returns
- ellipse radius in that direction
Definition at line 176 of file QPMath.cpp.
References Angle(), QPMath::Cos(), QPMath::Power(), QPMath::Sin(), and QPMath::Sqrt().
Referenced by EllipseUniAxis(), QPMath::WoodSaxon::RotAxis2D(), and QPMath::WoodSaxon::RotAxis2DUnsync().
◆ Angle()
| double QPMath::GeometryCalc::Angle | ( | double | x, |
| double | y, | ||
| double | centx = 0., |
||
| double | centy = 0. |
||
| ) |
Quadrant-aware angle of the point (x, y) about (centx, centy).
- Warning
- Through ATan2's swapped forwarding this evaluates std::atan2(x-centx, y-centy): the angle is measured from the +y axis, not from the +x axis as in the usual polar convention.
- Parameters
-
x point x y point y centx center x centy center y
- Returns
- angle in radians, measured from the +y axis
Definition at line 184 of file QPMath.cpp.
References QPMath::ATan2().
Referenced by EllipseRotAxis().